Research
RICAL Group, Georgia Tech
Ph.D. Student (Co-advised) · 2025 – present · Advisor: Dr. Yong K. Cho
- Robotics and intelligent automation for the construction domain.
- Wearable IMU-based worker-motion recognition and zone-level localization.
- Perception-to-decision vehicle monitoring for highway work-zone safety.
- See the Publications page for ongoing work.
HARMONIC Lab, Georgia Tech
Ph.D. Student (Co-advised) · 2025 – present · Advisor: Dr. Francis Baek
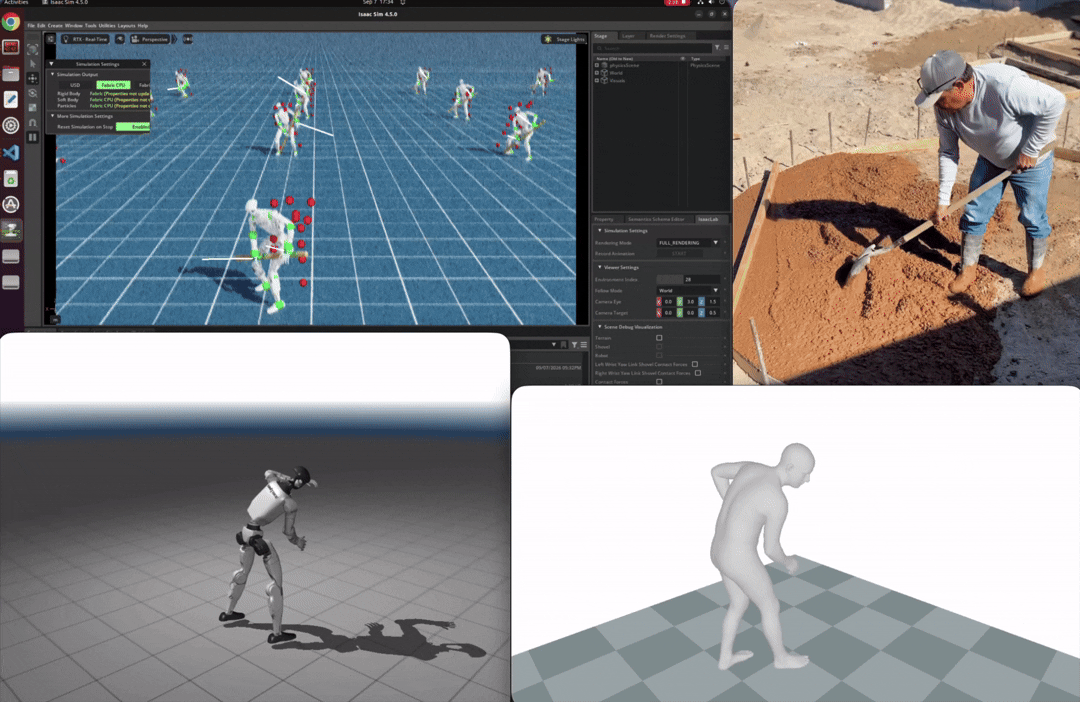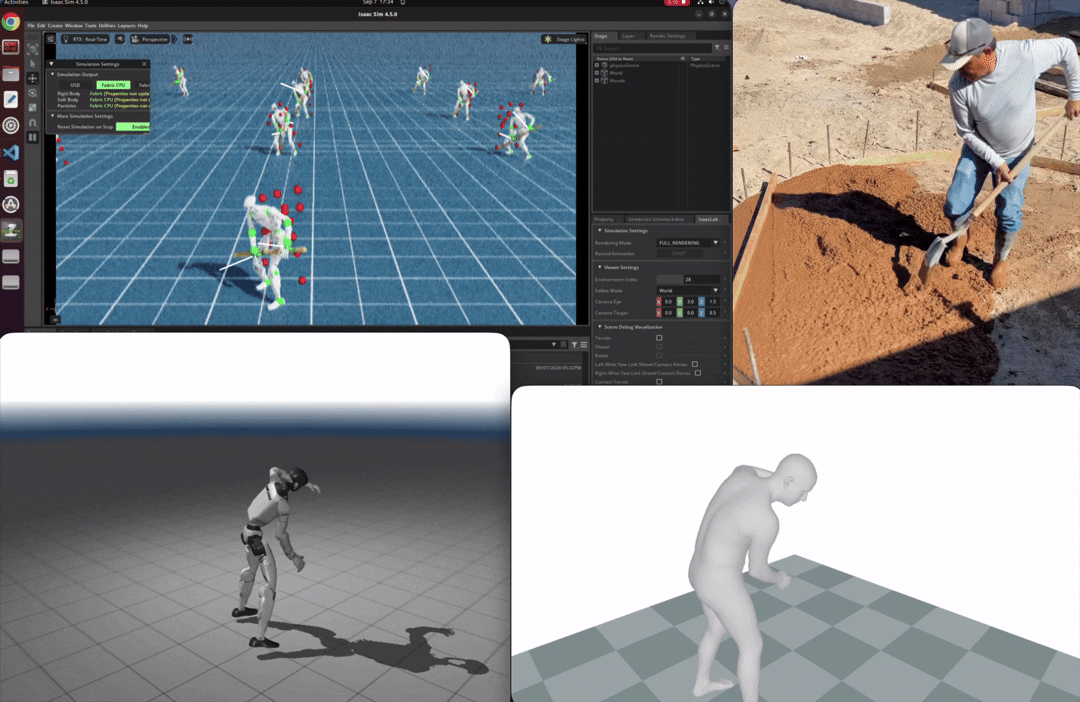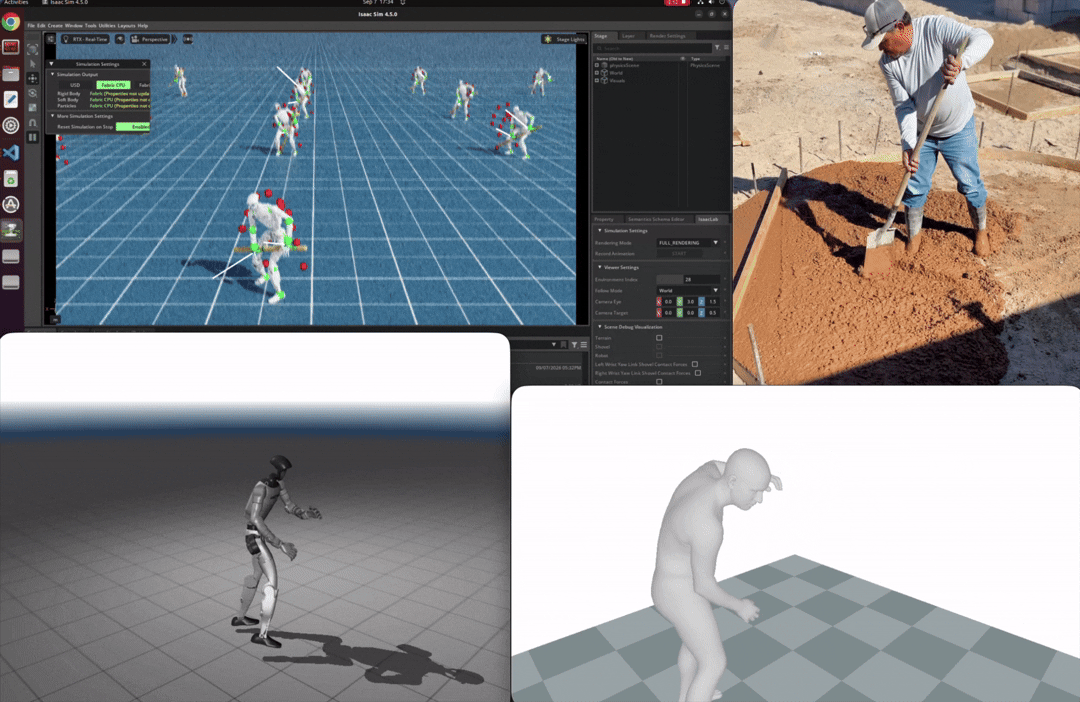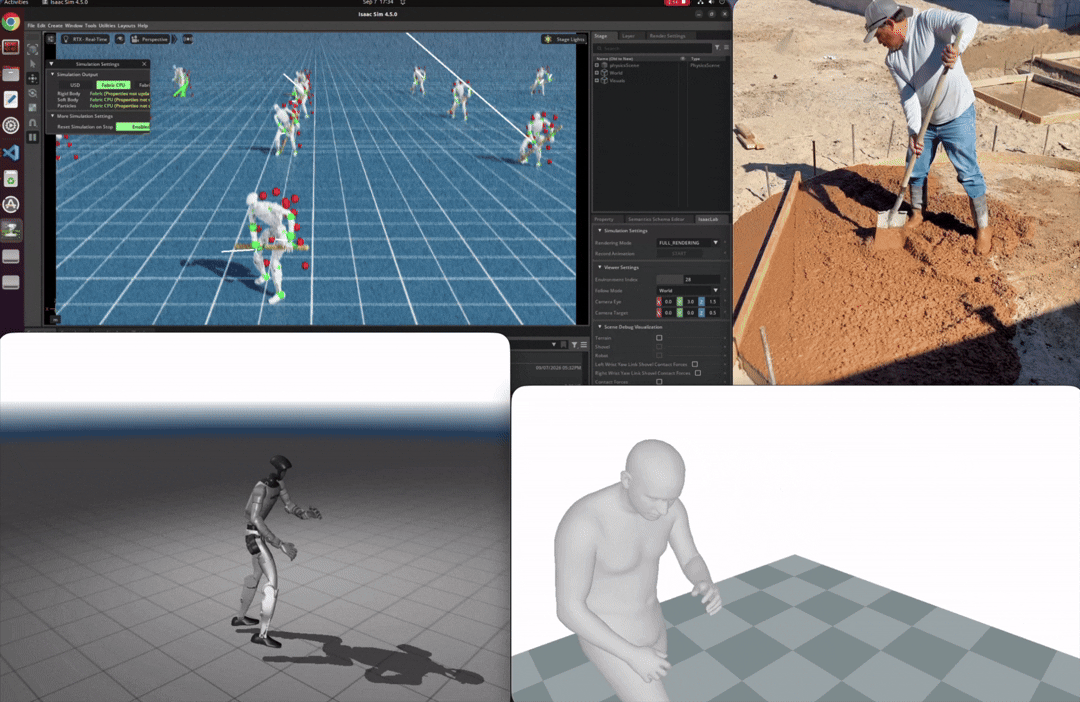
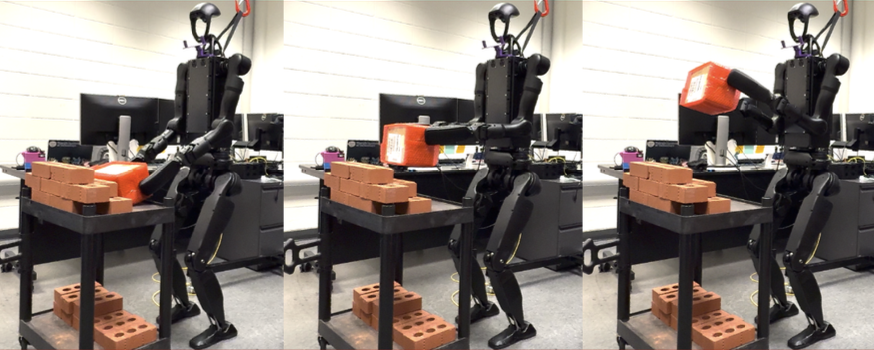
- Humanoid motion retargeting for construction and manufacturing field work.
- Retargeting objectives that preserve task structure while solving configuration for the robot’s own body.
- Reinforcement learning of tracking policies for tool-use and material-handling operations.
- Worker motion transfer from video with segmented motion classification, toward a reusable library of field operations.
- Human–robot interaction (HRI) for robots operating in construction and manufacturing environments.
- LLMs as virtual personas for estimating construction-practitioner perceptions of robotic automation.
- See Humanoid Motion Retargeting, Worker Motion Transfer from Video and Publications.
Snapshots